ONE SIMULATED STATE
A pedestrian ahead, a no-entry sign, then a junction.
CAMERA / GUIDED FLIGHTDECISION TREE → 3 CONTROLS AT THE CROSSING × 2 SIDES AT THE SIGN × 3 OPTIONS AT THE JUNCTION (SLOW BRANCH, 15 → 30 s)
H3 · 0 → 15 sCHASE CAMERA
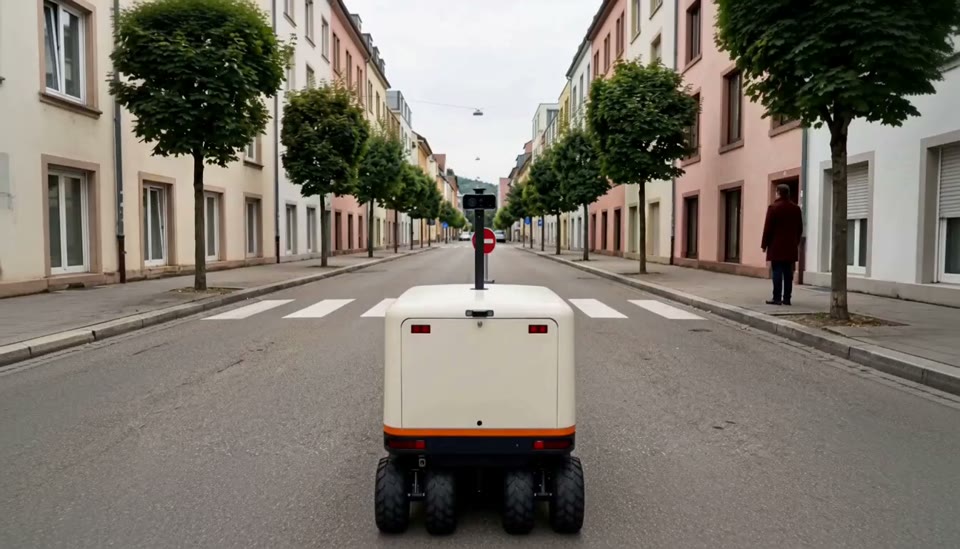
0.00 / 15.00s
F000
RENDER CHECK
One state. Three decisions. Twelve possible futures.
SIM → RENDER → VERIFYDRAG TO ORBIT · SCROLL TO ZOOM
TIME / SERIESSIMULATED
MIN DISTANCE ROBOT ↔ PEDESTRIAN— m
0 sSIMULATOR · 15 s
PIPELINE / TRACEREADY
1 · ≥ 1.0 m from the pedestrian, then fastest. 2 · Sign in own lane if ≥ 0.5 m clear. 3 · ≥ 1.0 m from the cyclist, then shortest route.
01 SIMULATE→02 RANK→03 H3 RENDER→04 VERIFY
EVENT / LEDGERREPLAY
SIM.STATEcrossing · pedestrian scriptedok
PLANNER.RANKslow → right → wait·
H3.REF2V · 15 s10 renders·
SAM3.VERIFYpending·
WORLDLINE / SIMULATION → H3LOADING RENDERS 00 / 19
3D frames, verification data and the first videos